
Last Updated on October 5, 2026 by Maged kamel
Estimation of Max and Min-Moment of Inertia for a Section.
Steps to obtain the expressions for I_max and I_min (moments of Inertia) and tan(2θ).
Our bending stress calculation is based on the pure Moment assumption, and we set the Product of Inertia, Ixy, to zero.
The neutral axis, for which Ixy = 0, must pass through the Cg.
The principal axes are two perpendicular axes with Ixy = 0.
We must examine both orthogonal axes when estimating Ixy and find that it is nonzero, since Ixy = 0 would imply Ixy = 0.
Numerous axes can be used to obtain l-polar = Ix+Iy or = Ix1+Iy1 or Ix’+Iy’ because the Value of I-polar is constant. However, the axes that will produce the Moment of Inertia are the ones that we are interested in; for instance, x’ will make the largest Moment of Inertia, and y ‘ will provide the smallest, and Ix’y’ should equal zero simultaneously.
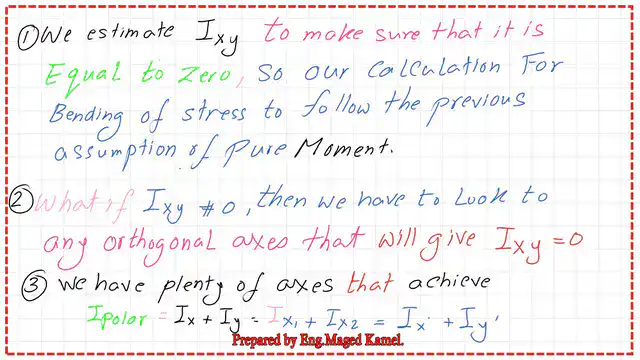
If Ix is maximum, Iy is minimum, and Ixy is zero, then any two axes are principal axes. The term “principal axes” refers to these two axes.
Derive the Expression for the maximum and minimum Moment of Inertia.
Using the x and y axes, we will create a general Expression and assume that we have two inclined axes, x’ and y’, with an angle of = θ, where θ is positive and pointing counterclockwise. To relate (x’ and y’) to x and y, for a small strip dA, the coordinates X and Y refer to the new axes (x’ and y’).
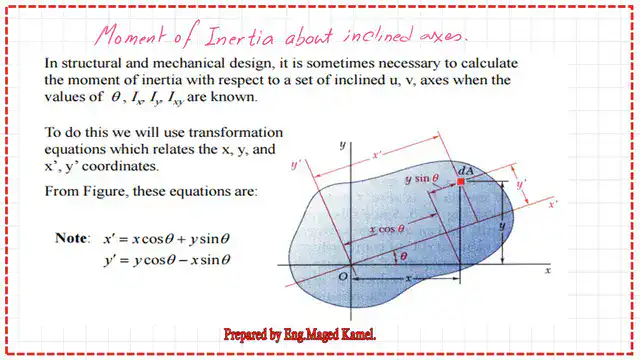
The formula for x’ is x cos θ + y sin θ. This part of x’ is represented by y’=ycosδ -xsinδ.
Then, since we know that Ix’ = ∫ dA*y’^2, this is the dA, and we wish to make an integration about x’; we continue to calculate the Moment of Inertia about x’ and y’ while also attempting to obtain an equation for Ix’ and Iy ‘ for the special case where Max and min moments of Inertia are needed. However, it will be = ∫ dAx’^2 for the Moment of Inertia about y’. Conversely, for the Inertia Product Ix’y ‘, = ∫ dAx’y’.
Substitute x’=x cos θ+y sin θ and y’=y cosδ -x sinθ. The following graphic shows we have Ix’, Iy’, and Ix’y’. These items are written after substituting x’, y’, and z ‘ in terms of x and y.
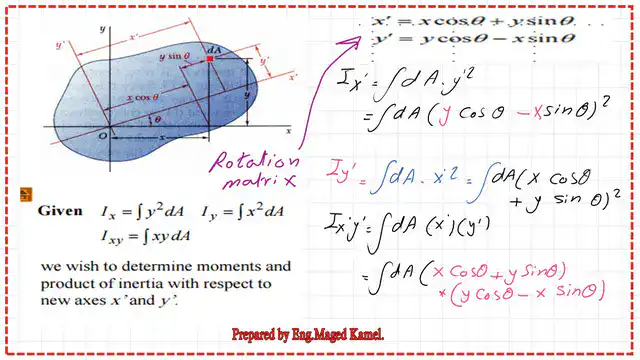
This calculation is lengthy, but our goal is to obtain three expressions. In terms of x, y, and angle θ—the angle enclosed between axis x and axis x’—the first Expression is for Ix’.
In terms of x, y, and angle θ—the angle enclosed between axis x and axis x’—the second Expression is for Iy’. For x and y, the third Expression is for Ix’y’, where θ is the angle between axes x and x’.

Since the polar of Inertia is equal to Ix + Iy, the first two expressions for Ix’ and Iy are displayed in the next slide.
Once we sum up Ix and Iy from Ip, we can obtain the Expression for tan(2θp).
We can add Ix and Iy from Ip to get an Expression for tan(2θp).
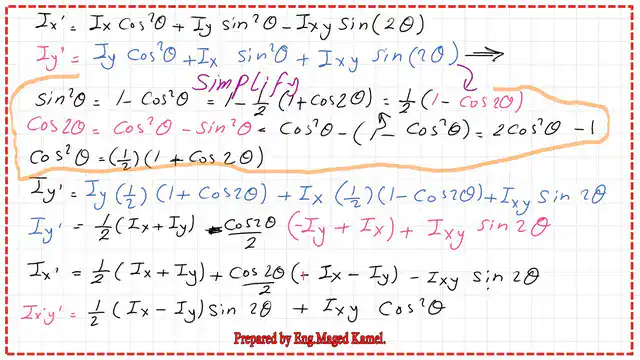
The angle θp, which produces Ix max and Iy min, can be obtained by differentiating Ix’ with respect to θ and setting it equal to zero.
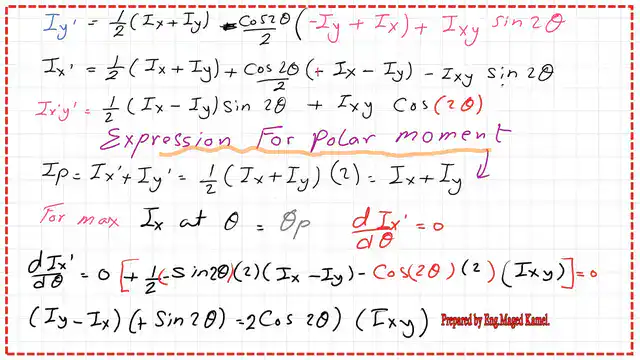
The Expression for the maximum and minimum moments of Inertia and the principal angle θp.
The principal angle θp is the angle between the x-axis and the principal axis of Inertia. We use twice the principal angle in the Mohr circle of Inertia.
The tan(2θp) is expressed as tan(2θp)=2(Ixy)/(Iy-Ix). Using this Expression, we can rewrite it to get (-2Ixy/(Ix-Iy) as the denominator for θp. When we set θ equal to θp, we can plug in the expressions for Ix’ and Iy’ and substitute θp. Then we can get the Max and Min-Moment of Inertia Expression. Please refer to the image on the next slide for more information.

The four cases for the relations between Ix, Iy, and Ixy.
We have obtained the enclosed angle, principal axis θp, between the X- and X’-axes, as needed to formulate the tan2θ Expression. We present four cases: first, Ix > Iy with Ixy positive.
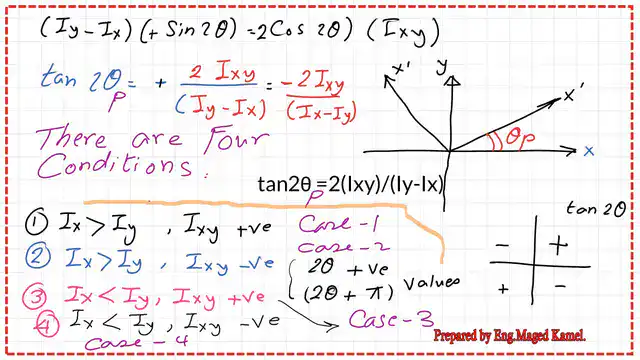
The second case is when Ix > Iy and Ixy is negative. The third case is when Ix < Iy and Ixy is positive. The fourth case is when Ix < Iy and Ixy is negative.
A video is available for this Post.
You can view or download the PDF data for this Post by clicking the following button.
The following Post is an Easy introduction to Mohr’s Circle of Inertia, Part 1.
This links to a valuable external resource: a calculator for cross-section, Mass, Axial and Polar Area Moment of Inertia, and Section Modulus.