
Last Updated on October 5, 2026 by Maged kamel
Mohr’s Circle of inertia-fourth case.
In this Post, we will discuss Mohr’s Circle of Inertia, the fourth case. In this case, the Moment of Inertia about the x-axis is less than that about the y-axis, and the Product of Inertia Ixy is negative.
We expect tan 2θp to be negative from the equation tan 2θp, since Ixy is negative.

What is the orientation of the principal axes for Mohr’s Circle of the inertia-fourth case?
We have the general Expression for the Moment of Inertia for any oriented axis; we call it Ix’. For Mohr’s Circle of the inertia-fourth case, the Value can be a maximum when cos2θ is negative and sin(θ) is positive. This angle is called 2φp1 or ( 2θp1). This angle is measured from the x-axis.
The other 180-degree direction has an angle of 2φp2 (or 2θp2), also measured from the x-axis, but it has a positive cosine and a negative sine.
The angle 2φp1 lies in the second quadrant, while angle 2φp2 lies in the fourth quadrant.

The steps used to draw Mohr’s Circle of inertia-fourth case.
The first two steps are to draw the two orthogonal axes. The first axis represents the Moment of Inertia values (Ix, Iy, and Imax) and the minimum values, while the second axis represents the Product of Inertia (Ixy).
Point A has coordinates (Ix, -Ixy), with -Ixy taken from the case data.
Point B has coordinates (Iy, +Ixy), and Ixy is the negative Value identical to the Ixy of Point A. Locate Points A and B with their respective Ix and Iy values, as shown in the next slide image.
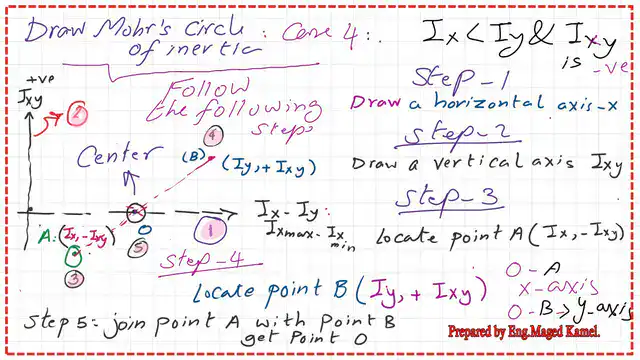
Join Points A and B and get the Midpoint of line AB, which is the center of the Circle.
The radius Value is the sqrt( (Iy-Ix/2)^2+Ixy^2).
Start at Point O and draw the Circle with the estimated radius. The Circle will intersect the line at two points, C and E.

Need for two mirror points A’ and B’ in Mohr’s Circle of inertia-fourth case.
Setting Point A’, which is a mirror of Point A and has a coordinate of (Ix,+Ixy), gives the direction of the maximum Moment axis U.
This Point A’ will enable us to rotate the x-axis or line OA clockwise by the Value of 2φp1. The x-axis will be horizontal, and the U line will also have a new direction represented by line OA’.
Point B’ is the mirror of Point B and has coordinates (Iy,-Ixy) and is used to indicate the direction of the V-axis, which is the direction of the minimum Moment of Inertia axis.
Angle 2φp1 is the angle between the X-axis and the central axis U, which is the angle enclosed between OA and Line OE. Point E is the Point of maximum Inertia.
Angle 2φp2 is the angle between the x-axis and the minor axis V, which is the angle enclosed between OA and Line OC. Point C is the Point of minimum Inertia.
The distance from the vertical axis Ixy to Point C gives the minimum Inertia, while the distance from the same axis to Point E gives the maximum Inertia.
In the normal view, the x-axis is horizontal, whereas in Mohr’s Circle for the inertia-fourth case, it is oriented at an angle of 2φp1 from the U-direction.
From the relation for tan 2φp, we get a negative tangent Value, which means the V axis has an enclosed angle measured clockwise.
The angle 2φp1 can be estimated as equal to (180-2φp2).

The direction of U and V axes in Mohr’s Circle of inertia-fourth case.
Join points OA’ to get the U-direction or the major axis direction. Join the two points O and B’ to get the V- direction for the normal view, the view from which the x and y axes are orthogonal in the normal view.
The following slide image shows the directions of both the U and V axes.

In the standard view, where x and y are 90 degrees from each other, we join Point C with Point A’ to get the U direction. To get the V direction, the minor axis direction, we join Point C with Point B’. The following slide image shows the directions of both the U and V axes.

For the orientation of the two axes, Ixy and Ix, so that the x-axis is horizontal, we can find that Point E is the Point at which Ix’ = Ix at 2θ = zero and Ix’y’ =- Ixy, since the line OE is a horizontal line, while Point A’ has Ix’=Iy and Ix’y’=+Ixy.
This drawing satisfies the Case-4 requirement that Ix < Iy and Ixy < 0.
An angle of (φp2) rotates the V axis clockwise from axis X, while the U axis rotates by an angle of (2φp1) anticlockwise from axis X.

You can download and review this Post’s content in the following PDF file.
In the next Post (13), we will solve a Problem covering Mohr’s Circle of Inertia
Post 14: a solved Problem, the Inertia Value for a given direction.
This is a Link to a useful external resource—calculata- for Cross-section, Mass, Axial & Polar Area Moment of Inertia, and Section Modulus.